Lasantha Kulasooriya
I build AI agents that decide and act, not just answer.
I design and deploy production AI agents across orchestration, retrieval, and real-time voice, alongside computer vision at the edge. These systems run in front of real users in cloud and physical environments, so latency, recovery, and failure modes are design inputs, not afterthoughts.
Selected Work
10 / projects
Who Am I
about
..Most AI agent engineers have never shipped a system where a wrong decision has physical consequences.
I have.
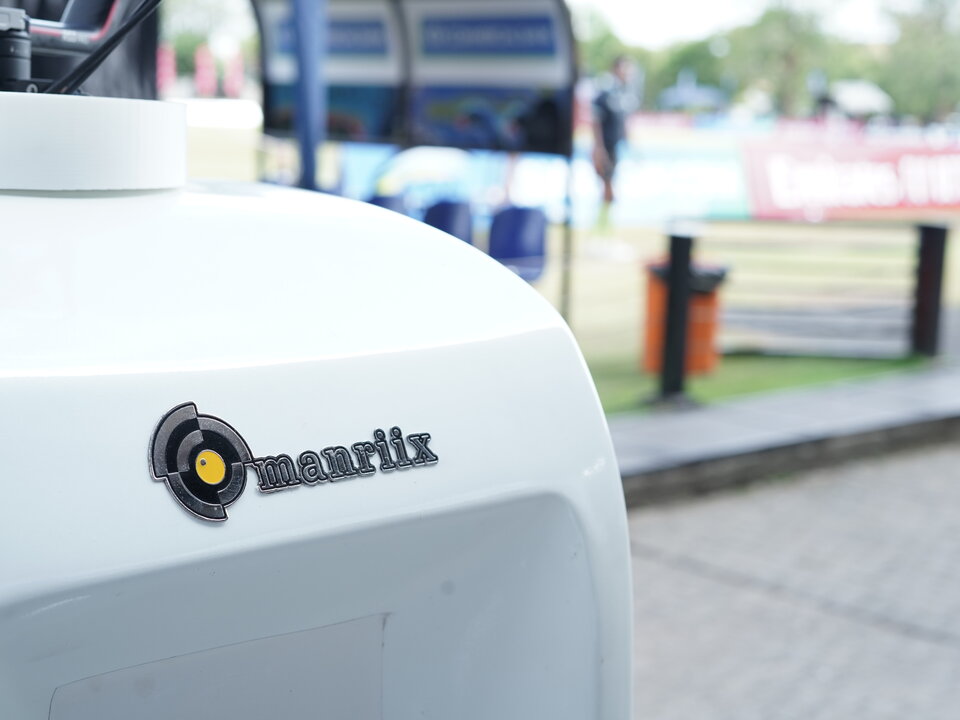
Since 2024 I've worked at Hype Insight Global, an Australian robotics company with a subsidiary office in Colombo, on Manriix, an interactive service robot. I wrote the BehaviorTree.CPP mission logic that decides what the robot does next, built its multi-camera perception pipeline, and, most recently, a cloud-edge voice AI platform that lets it hold a real-time conversation.
That work set the bar for what "reliable" means to me. A behavior tree can't retry indefinitely, so I bring that same discipline to AI agents: systems that call tools, retrieve context, and act on it correctly, not just generate plausible text.
I started in insurance data science at Janashakthi Insurance, building a claim-prediction model that outperformed the baseline before I ever touched a robot. Today I maintain gst-nvdsvpistereo, an open-source Jetson stereo-depth plugin I validated against physical tape-measure ground truth before trusting it in production. That's the discipline I've built across both halves of my career: document decisions as I make them, verify before I trust a result, and treat reliability as a design input, not an afterthought. It's the same standard whether it's a robot operating next to a person or an agent deciding which tool to call. Outside of that, I'm usually at the gym, making chicken curry, or watching a show.
Agents & Orchestration
Autonomous decision logic and multi-agent systems: behavior trees, LLM agents, production reliability.
Physical AI & Robotics
ROS 2 systems that run on real hardware: safety behavior, navigation recovery, human-aware robot control.
Applied LLM Systems
RAG pipelines and document intelligence wired into real workflows, not notebooks.
Voice & Realtime AI
Low-latency STT/TTS, voice interruption handling, and cloud-edge session architecture.
Edge AI & Perception
Real-time computer vision on Jetson: stereo depth, multi-camera fusion, TensorRT and CUDA optimization.
AI Platform Engineering
Cloud-edge architecture, production backends, and deployment sync that never blocks a live session.
Journey
experience & educationOwn the AI and robotics architecture behind Manriix, from behavior-tree decision logic to the voice platform it runs on.
- Wrote the BehaviorTree.CPP mission executor coordinating the robot's safety, voice interruption, navigation recovery, docking, and operator-assist behavior, with atomic mission-state persistence so an interrupted session resumes cleanly on restart.
- Designed the cloud-edge architecture for the robot's voice AI platform, LiveKit, Deepgram, OpenAI, and ElevenLabs behind one agent runtime, with MQTT deployment sync so a live conversation never blocks on a cloud read.
- Built a Jetson AGX Orin voice-guided photo capture system combining YOLO11-pose, MediaPipe, and RealSense depth to position people and trigger Canon camera capture through gimbal control.
- Documented 20 architecture decisions and ran a self-authored production-readiness audit before shipping, closing 5 blocking issues without being asked to.
Built the perception and camera systems that let Manriix operate autonomously around people.
- Built the multi-camera perception and navigation-decision pipeline, sustaining ~19fps detection across 3 ZED X cameras at 20–30% GPU utilization, with BIRCH clustering and an 8-level recovery architecture for degraded perception or navigation states.
- Built the robot's camera-control subsystem, integrating Canon R6 Mark II capture, video recording, and live streaming with hardware-accelerated encoding to keep camera I/O reliable under concurrent load.
- Built the photo-retrieval service that watches capture sessions in real time and hands processed images off to the robot's frontend.
Applied predictive modeling and analytics to insurance operations, from claim risk to real-time KPI reporting.
- Built a deep learning claim-prediction model that outperformed the baseline.
- Designed a personalized policy recommendation system for insurance agents; became my undergraduate thesis.
- Built the real-time KPI pipeline and leaderboard for DriveMe 2024, the company's annual sales competition.
Writing
notes & articlesI write about the engineering decisions, mathematics, and lessons behind the AI systems I build.